
Section 3.4.5 · Chapter 3: Creating Panel Applications
Sub-link Settings
An RS485 link or a Ethernet link can have many slave devices connected to it. The HMI uses the same communication protocol to talk with all the slave devices. The connection between the HMI and each of the slave devices is a sub-link. With the Sub-link table, the operator can enable or disable a sub-link at any time.
This section describes how to define the sub-links within a direct link using the Sub-link page of the Link Properties dialog box. The following is an example of the Sub-link page
for a RS-485 link.
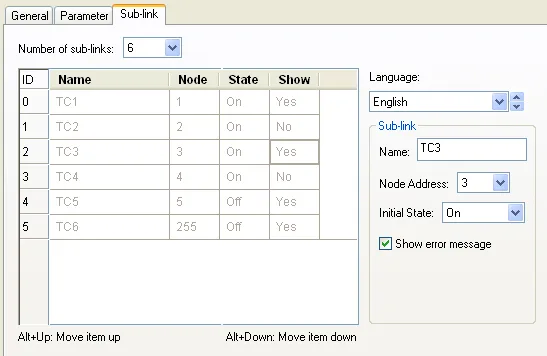
The following is an example of the Sub-link page for an Ethernet link.
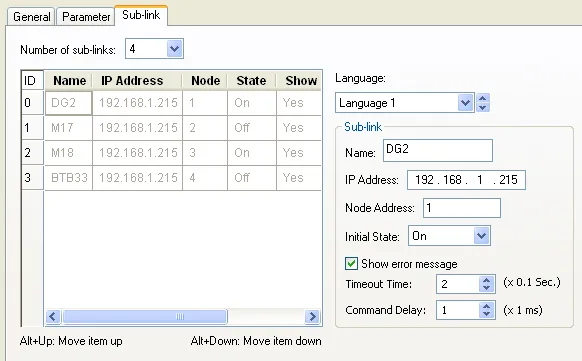
The following table describes each property in the Sub-link page of the Link Properties dialog box for a direct link.
|
Property |
Description | |
|---|---|---|
| Number of sub-links | Specifies how many devices the link will connect as sub-links. | |
| Language | Specifies the current language for the Name field. | |
| Name | The name of the selected sub-link for the language specified in the Language field. | |
| IP Address | The IP address of the connected device. | |
| Node Address | The address of the selected sub-link. The address must be a unique number within all the sub-links. | |
| Initial State | The initial communication state for the selected sub-link. If the state is On, the panel will communicate with the sub-link after running the application. If the state is Off, the panel will not communicate with the sub-link until the communication state is turn On in a sub-link table. | |
| Show error message | If this option is checked, the communication error message will be shown when the selected sub-link encounters communication errors. If this option is unchecked, no error message will be shown for any communication errors. | |
| Timeout Time |
|
|
| Command Delay | If the Command Delay is 0, the communication driver immediately sends the next request to the connected device when it receives a reply from the last request. If the Command Delay is nonzero, the communication driver delays for the specified amount of time before sending the next request to the connected device. |
Need PM Designer itself?
V4 for current PK, PT, ITV and PM panels, V2 for older models. Free, sent by email.
Source.Section 3.4.5 of the PM Designer Software User Manual, Edition 2.0, © Cermate Technologies Inc. (www.cermate.com, service@cermate.com). Reproduced online, with the manual's own figures, by TSL Automation Solutions, authorised Cermate distributor, for users of Cermate HMI panels. PM Designer and PanelMaster are trademarks of Cermate Technologies Inc.
Text and figures are the manufacturer's and may describe features your panel or software version does not have. For a plain-language introduction read the PM Designer guide; for help with a specific panel contact TSL Automation.